



Sistema de seguridad Arduino: Detección de movimiento inteligente y alerta
Componentes y suministros
| Componente | Cantidad |
|---|---|
| Arduino UNO | 1 |
| Sensor ultrasónico HC-SR04 (genérico) | 1 |
| Servo (Tower Pro MG996R) | 1 |
| Zumbador (buzzer) | 1 |
| Protoboard (genérica) | 1 |
| Cables puente Macho/Hembra | 1 |
| Caja de plástico | 1 |
Herramientas y máquinas necesarias
- Cuchillo
Aplicaciones y servicios en línea
- Arduino IDE
- Processing IDE
Sobre este proyecto
Introducción


Este proyecto es un Sistema de Seguridad basado en Arduino que consiste en un Arduino Uno, un motor servo, un sensor ultrasónico y un zumbador piezoeléctrico.
Aquí, el sensor ultrasónico detecta un objeto que está dentro de su rango, lo que activa el zumbador. Estos datos del sensor también se envían al software Processing IDE, que crea un mapa gráfico tipo radar.
El motor servo se usa para rotar el sensor ultrasónico y así cubrir un área amplia.
Este es un proyecto bastante simple y puede realizarse en una hora.
Procedimiento del proyecto
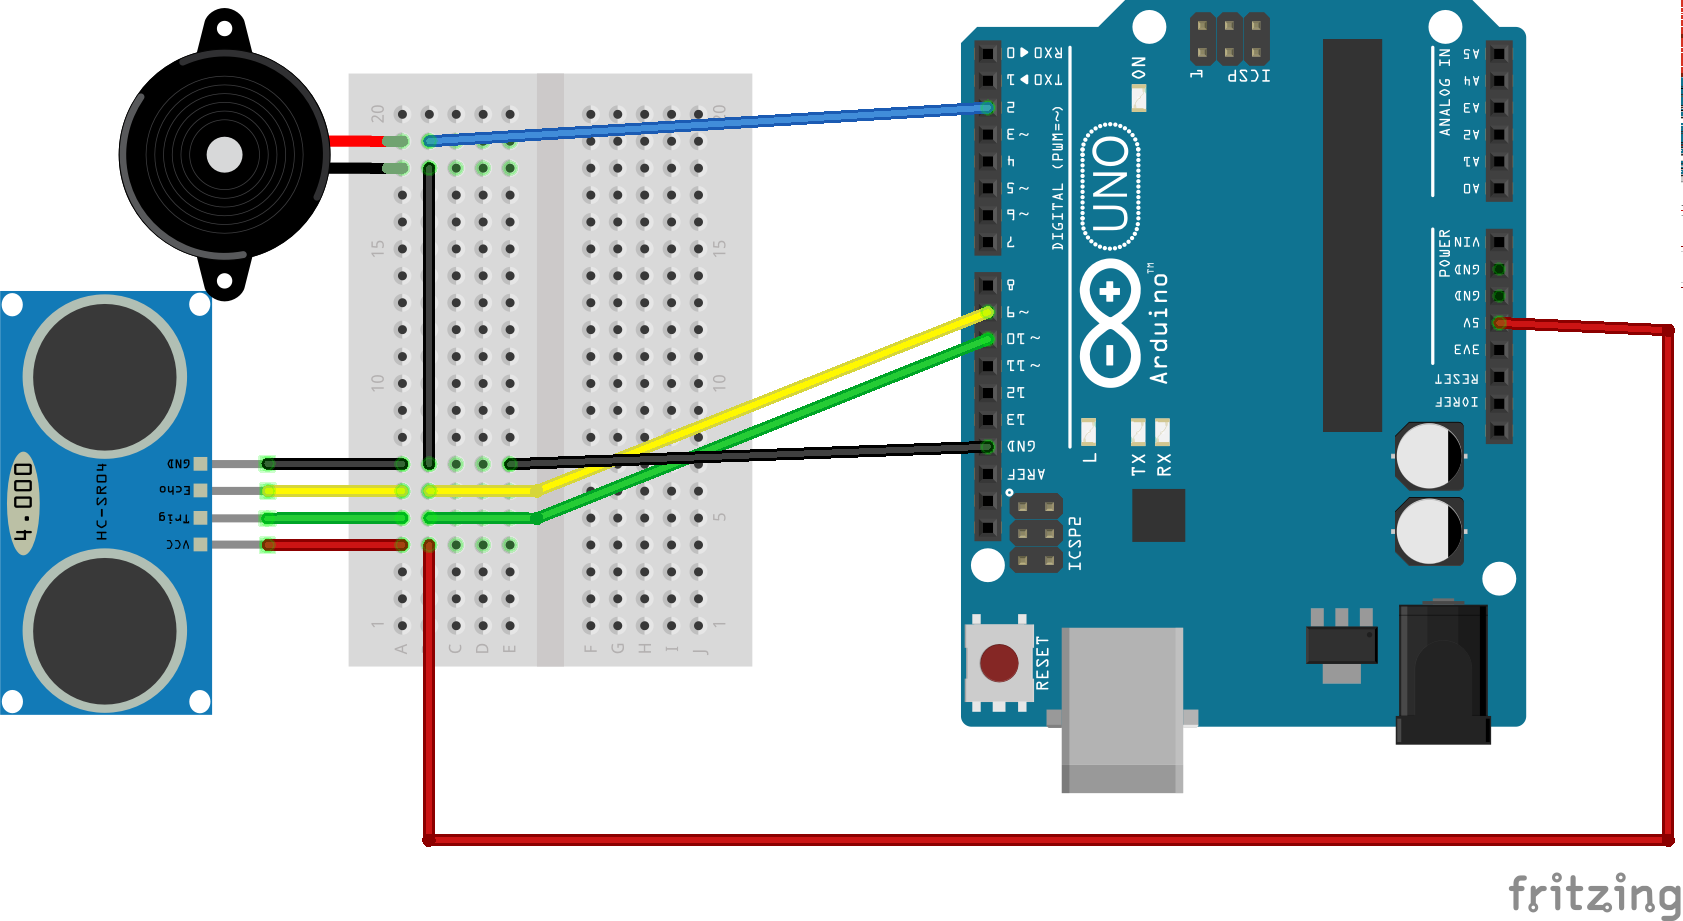
- Conecta el pin Trigger del sensor al pin 2 del Arduino
- Conecta el pin Echo del sensor al pin 3 del Arduino
- Conecta Vcc y GND del sensor a Alimentación y Tierra respectivamente
- Coloca el zumbador en la protoboard
- Conecta su terminal positivo al pin 10 del Arduino y el negativo a tierra
- Conecta el cable negro y rojo del servo a tierra y alimentación respectivamente
- Conecta el cable amarillo del servo al pin 9 del Arduino
- Conecta el terminal 5V del Arduino a alimentación y GND a tierra
Después de terminar estas conexiones, coloca todo el circuito dentro de la caja como se muestra en la figura.
Luego es hora de programar.
Código
Security System_IDE (C/C++)
#include <Servo.h>

int tPin = 2;
int ePin = 3;
int buz = 10;
int d1, d2;
int i = 0;
int sdistance;
Servo myServo;

void setup() {
  Serial.begin(9600);
  pinMode(tPin, OUTPUT);
  pinMode(ePin, INPUT);
  pinMode(buz, OUTPUT);
  myServo.attach(9);
}

void loop() {
  for (i = 0; i <= 180; i += 10) {
    myServo.write(i);
    delay(30);
    d2 = calculateDistance();
    Serial.print(i);
    Serial.print(",");
    Serial.print(d2);
    Serial.print(".");
  }
  for (i = 180; i > 0; i -= 10) {
    myServo.write(i);
    delay(30);
    d2 = calculateDistance();
    Serial.print(i);
    Serial.print(",");
    Serial.print(d2);
    Serial.print(".");
  }
}

int calculateDistance() {
  digitalWrite(tPin, HIGH);
  delay(1000);
  digitalWrite(tPin, LOW);
  d1 = pulseIn(ePin, HIGH);
  d2 = d1 * 0.0171821306;
  if (d2 < 10) {
    digitalWrite(buz, HIGH);
  } else {
    digitalWrite(buz, LOW);
  }
  return d2;
}
Processing (Java)
import processing.serial.*;
import java.awt.event.KeyEvent;
import java.io.IOException;

Serial myPort;
String angle = "";
String distance = "";
String data = "";
String noObject;
float pixsDistance;
int iAngle, iDistance;
int index1 = 0;
int index2 = 0;
PFont orcFont;

void setup() {
  size(1366, 768); // ***CAMBIA ESTO A TU RESOLUCIÓN DE PANTALLA***
  smooth();
  myPort = new Serial(this, "COM3", 9600);
  myPort.bufferUntil('.');
}

void draw() {
  fill(98, 245, 31);
  noStroke();
  fill(0, 4);
  rect(0, 0, width, height - height * 0.065);
  fill(98, 245, 31);
  drawRadar();
  drawLine();
  drawObject();
  drawText();
}

void serialEvent(Serial myPort) {
  data = myPort.readStringUntil('.');
  data = data.substring(0, data.length() - 1);
  index1 = data.indexOf(",");
  angle = data.substring(0, index1);
  distance = data.substring(index1 + 1, data.length());
  iAngle = int(angle);
  iDistance = int(distance);
}

void drawRadar() {
  pushMatrix();
  translate(width / 2, height - height * 0.074);
  noFill();
  strokeWeight(2);
  stroke(98, 245, 31);
  arc(0, 0, (width - width * 0.0625), (width - width * 0.0625), PI, TWO_PI);
  arc(0, 0, (width - width * 0.27), (width - width * 0.27), PI, TWO_PI);
  arc(0, 0, (width - width * 0.479), (width - width * 0.479), PI, TWO_PI);
  arc(0, 0, (width - width * 0.687), (width - width * 0.687), PI, TWO_PI);
  line(-width / 2, 0, width / 2, 0);
  line(0, 0, (-width / 2) * cos(radians(30)), (-width / 2) * sin(radians(30)));
  line(0, 0, (-width / 2) * cos(radians(60)), (-width / 2) * sin(radians(60)));
  line(0, 0, (-width / 2) * cos(radians(90)), (-width / 2) * sin(radians(90)));
  line(0, 0, (-width / 2) * cos(radians(120)), (-width / 2) * sin(radians(120)));
  line(0, 0, (-width / 2) * cos(radians(150)), (-width / 2) * sin(radians(150)));
  line((-width / 2) * cos(radians(30)), 0, width / 2, 0);
  popMatrix();
}

void drawObject() {
  pushMatrix();
  translate(width / 2, height - height * 0.074);
  strokeWeight(9);
  stroke(255, 10, 10);
  pixsDistance = iDistance * ((height - height * 0.1666) * 0.025);
  if (iDistance < 10) {
    line(pixsDistance * cos(radians(iAngle)), -pixsDistance * sin(radians(iAngle)),
         (width - width * 0.505) * cos(radians(iAngle)), -(width - width * 0.505) * sin(radians(iAngle)));
  }
  popMatrix();
}

void drawLine() {
  pushMatrix();
  strokeWeight(9);
  stroke(30, 250, 60);
  translate(width / 2, height - height * 0.074);
  line(0, 0, (height - height * 0.12) * cos(radians(iAngle)), -(height - height * 0.12) * sin(radians(iAngle)));
  popMatrix();
}

void drawText() {
  pushMatrix();
  if (iDistance > 10) {
    noObject = "Out of Range";
  } else {
    noObject = "In Range";
  }
  fill(0, 0, 0);
  noStroke();
  rect(0, height - height * 0.0648, width, height);
  fill(98, 245, 31);
  textSize(25);
  text("2cm", width - width * 0.3854, height - height * 0.0833);
  text("4cm", width - width * 0.281, height - height * 0.0833);
  text("6cm", width - width * 0.177, height - height * 0.0833);
  text("10cm", width - width * 0.0729, height - height * 0.0833);
  textSize(40);
  text("Akshay6766 ", width - width * 0.875, height - height * 0.0277);
  text("Angle: " + iAngle + " ", width - width * 0.48, height - height * 0.0277);
  text("Distance: ", width - width * 0.26, height - height * 0.0277);
  if (iDistance < 40) {
    text(" " + iDistance + " cm", width - width * 0.225, height - height * 0.0277);
  }
  textSize(25);
  fill(98, 245, 60);
  translate((width - width * 0.4994) + width / 2 * cos(radians(30)), (height - height * 0.0907) - width / 2 * sin(radians(30)));
  rotate(-radians(-60));
  text("30", 0, 0);
  resetMatrix();
  translate((width - width * 0.503) + width / 2 * cos(radians(60)), (height - height * 0.0888) - width / 2 * sin(radians(60)));
  rotate(-radians(-30));
  text("60", 0, 0);
  resetMatrix();
  translate((width - width * 0.507) + width / 2 * cos(radians(90)), (height - height * 0.0833) - width / 2 * sin(radians(90)));
  rotate(radians(0));
  text("90", 0, 0);
  resetMatrix();
  translate(width - width * 0.513 + width / 2 * cos(radians(120)), (height - height * 0.07129) - width / 2 * sin(radians(120)));
  rotate(radians(-30));
  text("120", 0, 0);
  resetMatrix();
  translate((width - width * 0.5104) + width / 2 * cos(radians(150)), (height - height * 0.0574) - width / 2 * sin(radians(150)));
  rotate(radians(-60));
  text("150", 0, 0);
  popMatrix();
}
Esquemas
Control preciso de motor paso a paso: 28BYJ-48 con Arduino UNO y joystick
Construye un dispensador inteligente de gel hidroalcohólico con Arduino - Guía DIY
Proceso de manufactura
- Detector de idiomas TinyML con Edge Impulse en Arduino Nano 33 BLE Sense
- Construye un Juego Giroscópico en Tiempo Real con Arduino Nano y Sensor MPU-6050
- Proyecto Dados Digitales Arduino: Construye tu Propio Generador de Números Aleatorios con LCD
- Construye un Iron Man animado con Arduino: componentes, sensores y guía paso a paso
- Find Me: Localizador Inteligente de Objetos con Arduino y Bluetooth
- Controlador de Humidificador DIY con Arduino y Relé: Configuración Segura de Alto Voltaje
- Medición de Distancia en Tiempo Real con Sonar Arduino y Visualización en Processing
- MobBob: Robot Arduino Impreso en 3D, Controlado por Smartphone Android
- Construir una lámpara de escritorio reactiva al audio con Arduino Nano
- Pong Neón en Matriz NeoPixel con Arduino Nano
- Construye un volante joystick personalizado con Arduino para gaming