



Maqueta de Parada de Autobús Inteligente con Toldos Automáticos
Componentes y suministros
| Componente | Descripción | Cantidad |
|---|---|---|
| Arduino Nano R3 | Pequeño, fácil de ocultar en maqueta. | 1 |
| Servo MG995 | Servo de alta potencia para toldo pesado. | 1 |
| Fotorresistencia | Una orientada Este, otra Oeste. | 2 |
| Sensor de lluvia | Detecta precipitación. | 1 |
| LED blanco alta luminosidad | Iluminación interior y farola. | 6 |
| Resistencia 220Ω | Para LEDs. | 3 |
| Protoboard | Conexiones. | 1 |
| Cables jumper Macho-Macho | 27 unidades. | 27 |
| Bornas de tornillo | Conexiones seguras. | 2 |
| Conector batería 9V | Para Arduino y servo. | 2 |
| Batería 9V | Alimentación Arduino. | 1 |
| Portabaterías 4xAA | Alimentación servo MG995. | 1 |
Sobre el proyecto
Versión 2.0 de maqueta arquitectónica (1.5m x 1m). Mejoras respecto a V1.0:
- Servo MG995 para toldo más pesado.
- Fuente externa para el servo.
- Dos mecanismos probados para desplegar/recoger toldo (el definitivo en video 3).
- Uso de librería
VarSpeedServopara movimiento suave. - Corrección lógica en estados del toldo (gracias a Gurneet1928).
Código
#include <VarSpeedServo.h>
VarSpeedServo servo;
int easternLight = 0, westernLight = 0, rainSensed = 0, sunshadePosition = 0;
int rainThreshold = 512;
int sunshadeExpanded = 120, sunshadeContracted = 60;
int ambientLighting = 0, turnOnLightsOn = 150, ledIntensity = 0, ledPower = 0;
int servoSpeed = 20;
bool debugging = false;

void setup() {
  pinMode(A4, OUTPUT); // Iluminación interior
  pinMode(A5, OUTPUT); // Farola
  pinMode(A1, INPUT);  // Luz Oeste
  pinMode(A2, INPUT);  // Luz Este
  pinMode(A3, INPUT);  // Sensor lluvia analógico
  pinMode(2, INPUT);   // Sensor lluvia digital
  servo.attach(A0);
  servo.write(sunshadeContracted, servoSpeed, true);
  if (debugging) { Serial.begin(9600); Serial.println("*** DEBUGGING STARTED ***"); }
}

void oya_mydebug(String text, int value = NULL) {
  if (debugging) {
    Serial.print(text);
    if (value) { Serial.print(" = "); Serial.println(value); }
    else Serial.println();
  }
}

void expand_collapse(int easternLight, int westernLight) {
  if (easternLight <= westernLight) { // Amanecer
    oya_mydebug("It's sunrise");
    if (sunshadePosition != sunshadeExpanded) {
      servo.write(sunshadeExpanded, servoSpeed, true);
      oya_mydebug("Sunshade expanded");
    }
  }
  if (easternLight > westernLight) { // Atardecer
    oya_mydebug("Sun is going down");
    if (sunshadePosition != sunshadeContracted) {
      servo.write(sunshadeContracted, servoSpeed, true);
      oya_mydebug("Sunshade contracted");
    }
  }
}

void loop() {
  easternLight = analogRead(A2);
  westernLight = analogRead(A1);
  rainSensed = analogRead(A3);
  sunshadePosition = servo.read();
  ambientLighting = (easternLight + westernLight) / 2;

  oya_mydebug("easternLight", easternLight);
  oya_mydebug("westernLight", westernLight);
  oya_mydebug("rainSensed", rainSensed);
  oya_mydebug("sunshadePosition", sunshadePosition);
  oya_mydebug("ambientLighting", ambientLighting);

  if (rainSensed < rainThreshold) { // Llueve
    oya_mydebug("It's raining...");
    if (sunshadePosition != sunshadeExpanded) {
      servo.write(sunshadeExpanded, servoSpeed, true);
      oya_mydebug("Sunshade expanded");
    }
  } else { // No llueve
    oya_mydebug("It is not raining...");
    if (ambientLighting <= turnOnLightsOn) { // Oscurece
      oya_mydebug("It's getting dark, turning on the lights");
      ledPower = ((turnOnLightsOn - ambientLighting) * 4);
      oya_mydebug("ledPower", ledPower);
      analogWrite(A5, ledPower);
      analogWrite(A4, ledPower);
      expand_collapse(easternLight, westernLight);
    } else { // Mucha luz
      oya_mydebug("A lot of sunshine, turn off lights");
      analogWrite(A5, 0); analogWrite(A4, 0);
      expand_collapse(easternLight, westernLight);
    }
  }
  if (debugging) { Serial.println("********************"); delay(5000); }
  else delay(100);
}
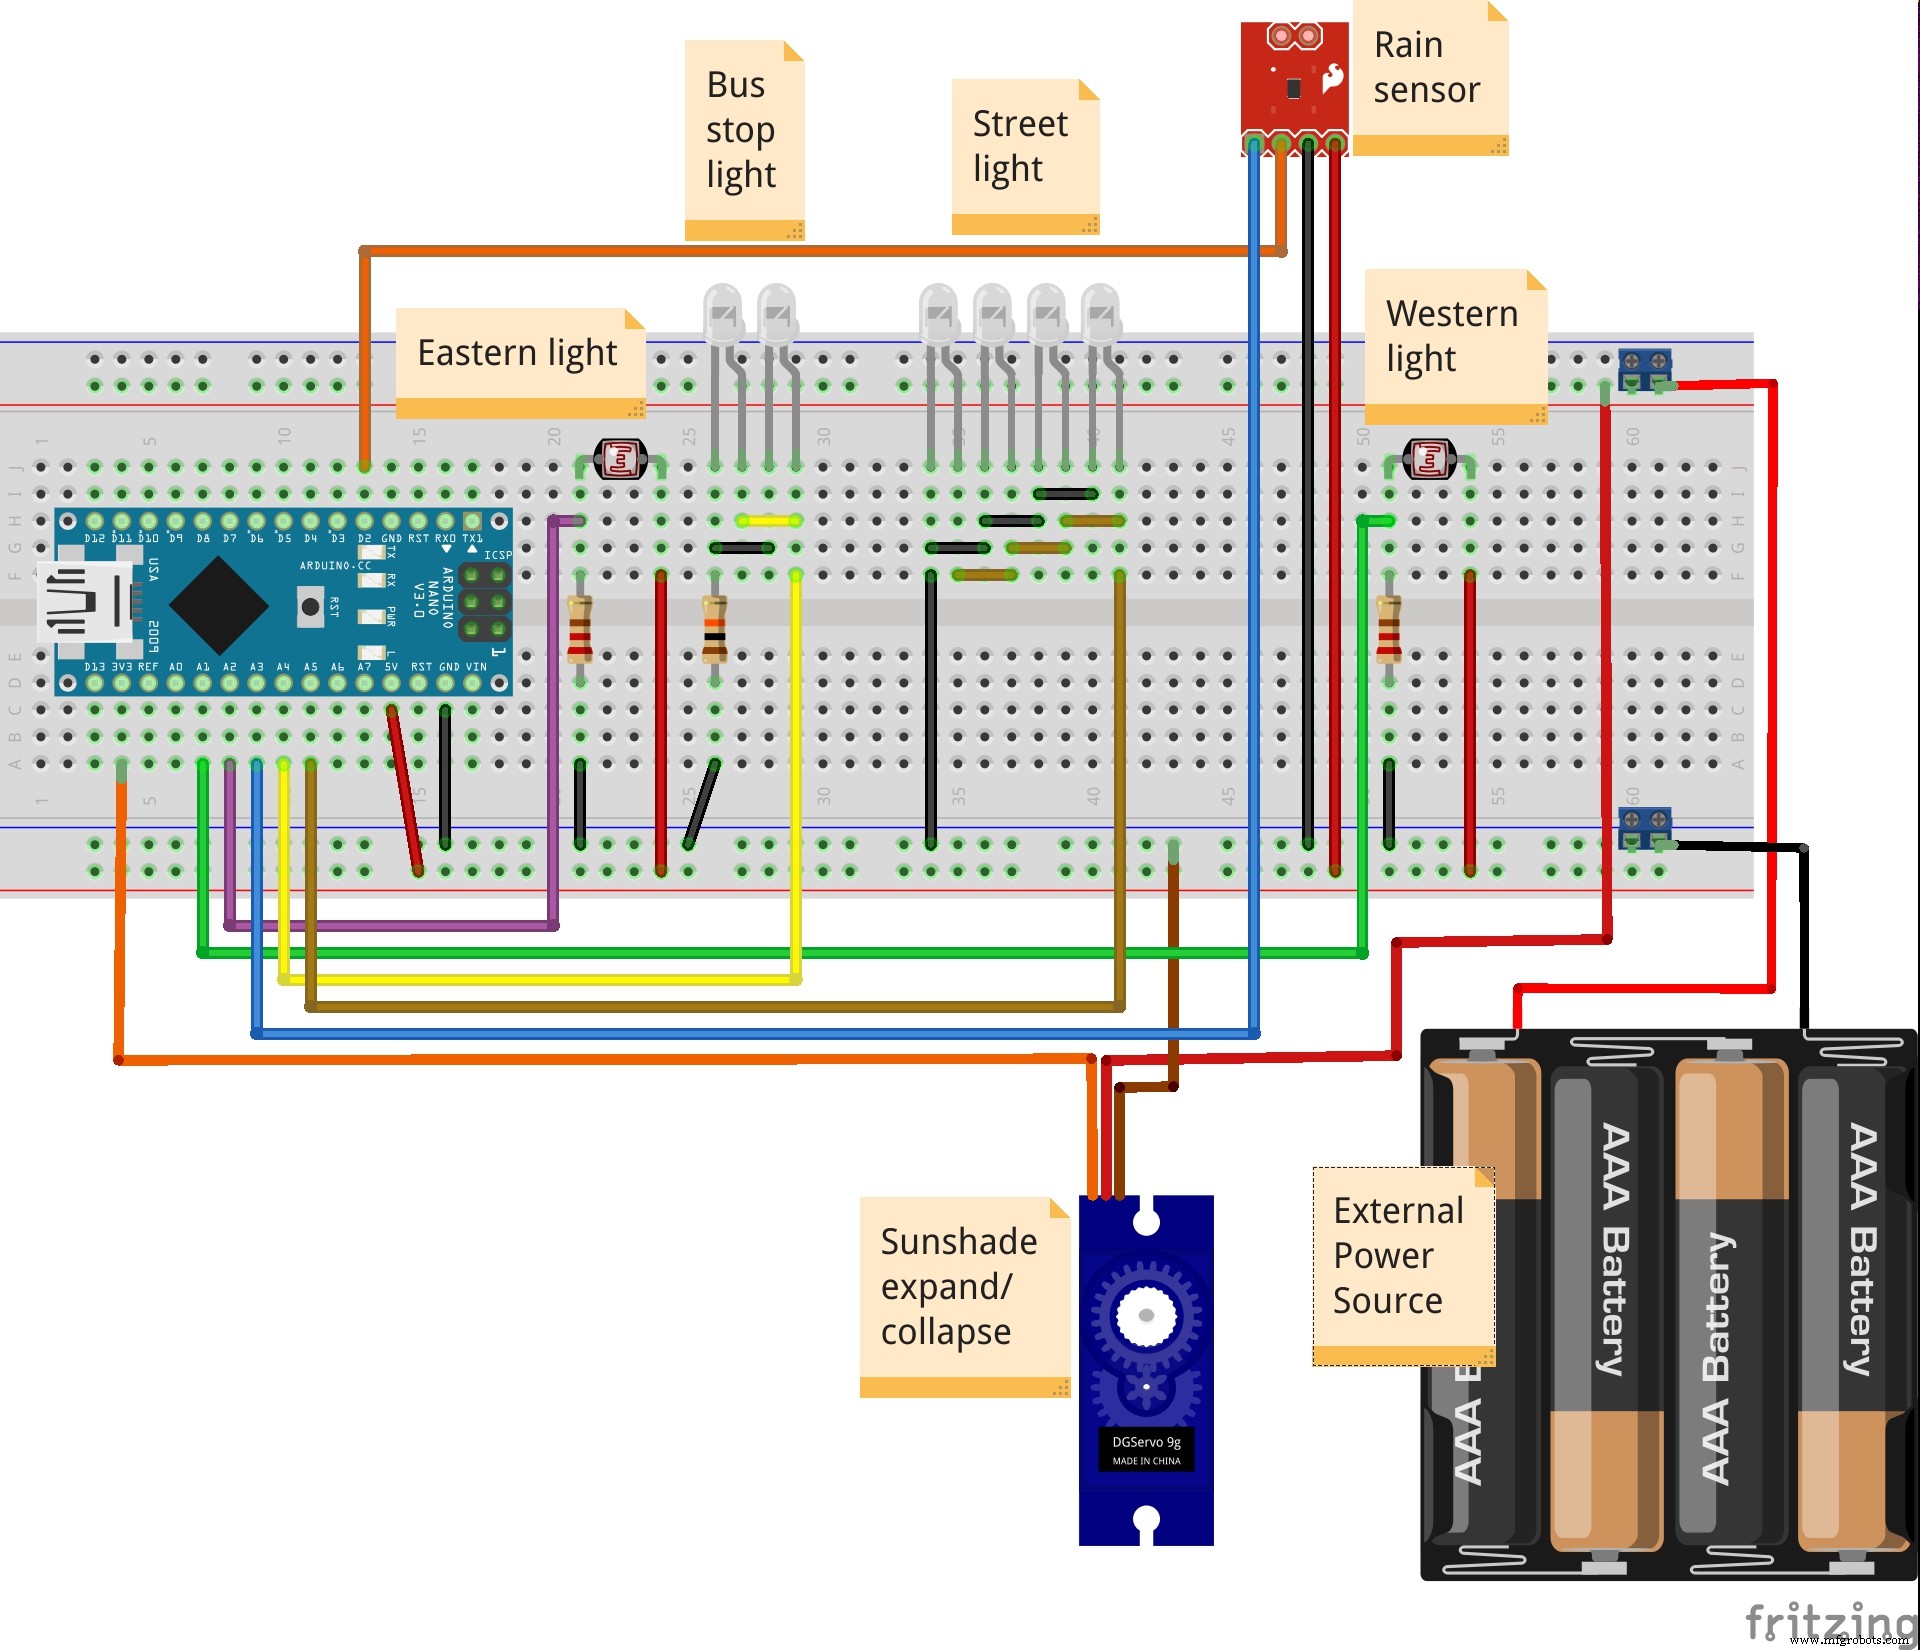
Esquemático
START: Terminal Arduino Autónoma con Teclado PS2, LCD, Ethernet y Shell Remoto
Sistema de Ventilación Inteligente para Sótanos: Control de Humedad con Arduino
Proceso de manufactura
- Trenes modelo Lionel: historia, fabricación y futuro
- Robot Clasificador de Reciclaje con Google Coral Edge TPU
- Control Automático de Tren DIY con Arduino: Simple, Fiable y Personalizable
- Robot evasor de obstáculos con servo: Construcción con Arduino y HC-SR04
- Sistema automático de riego para plantas con Arduino
- Fundamentos de la Prensa Servo: Potencia, Precisión y Eficiencia Explicadas
- Motores servo: funcionamiento, tipos y por qué son importantes
- Maximizando la precisión: Acoplamiento de reductores con servomotores
- Ciclo de Mandrinado ECS G86 con Función de Parada de Husillo
- Torno lineal SPRINT 20: Torneado automatizado rápido para piezas de alta precisión
- Maximice ingresos recurrentes con consumibles inteligentes: Un cambio de juego para fabricantes de maquinaria