



Construye una consola Pong 24×16 LED con Arduino Nano y MAX7219
Componentes y suministros
| Componente | Cantidad | Notas |
|---|---|---|
| Arduino Nano R3 | 1 | |
| Módulo matriz LED 8×8 con MAX7219 | 6 | Módulos listos de Aliexpress |
| Potenciómetro rotativo 10 kΩ (genérico) | 2 | Controles de paletas |
| Zumbador (buzzer) | 1 | Sonido |
Herramientas necesarias
- Soldador (genérico)
Aplicaciones y servicios en línea
- Arduino IDE
Sobre el proyecto
Construí esta pequeña consola Pong sobre un array de 6 matrices LED 8×8 siguiendo instrucciones y código de: Instructables – Pong.
En lugar de fabricar matrices a medida, compré módulos 8×8 con MAX7219 baratos en Aliexpress.
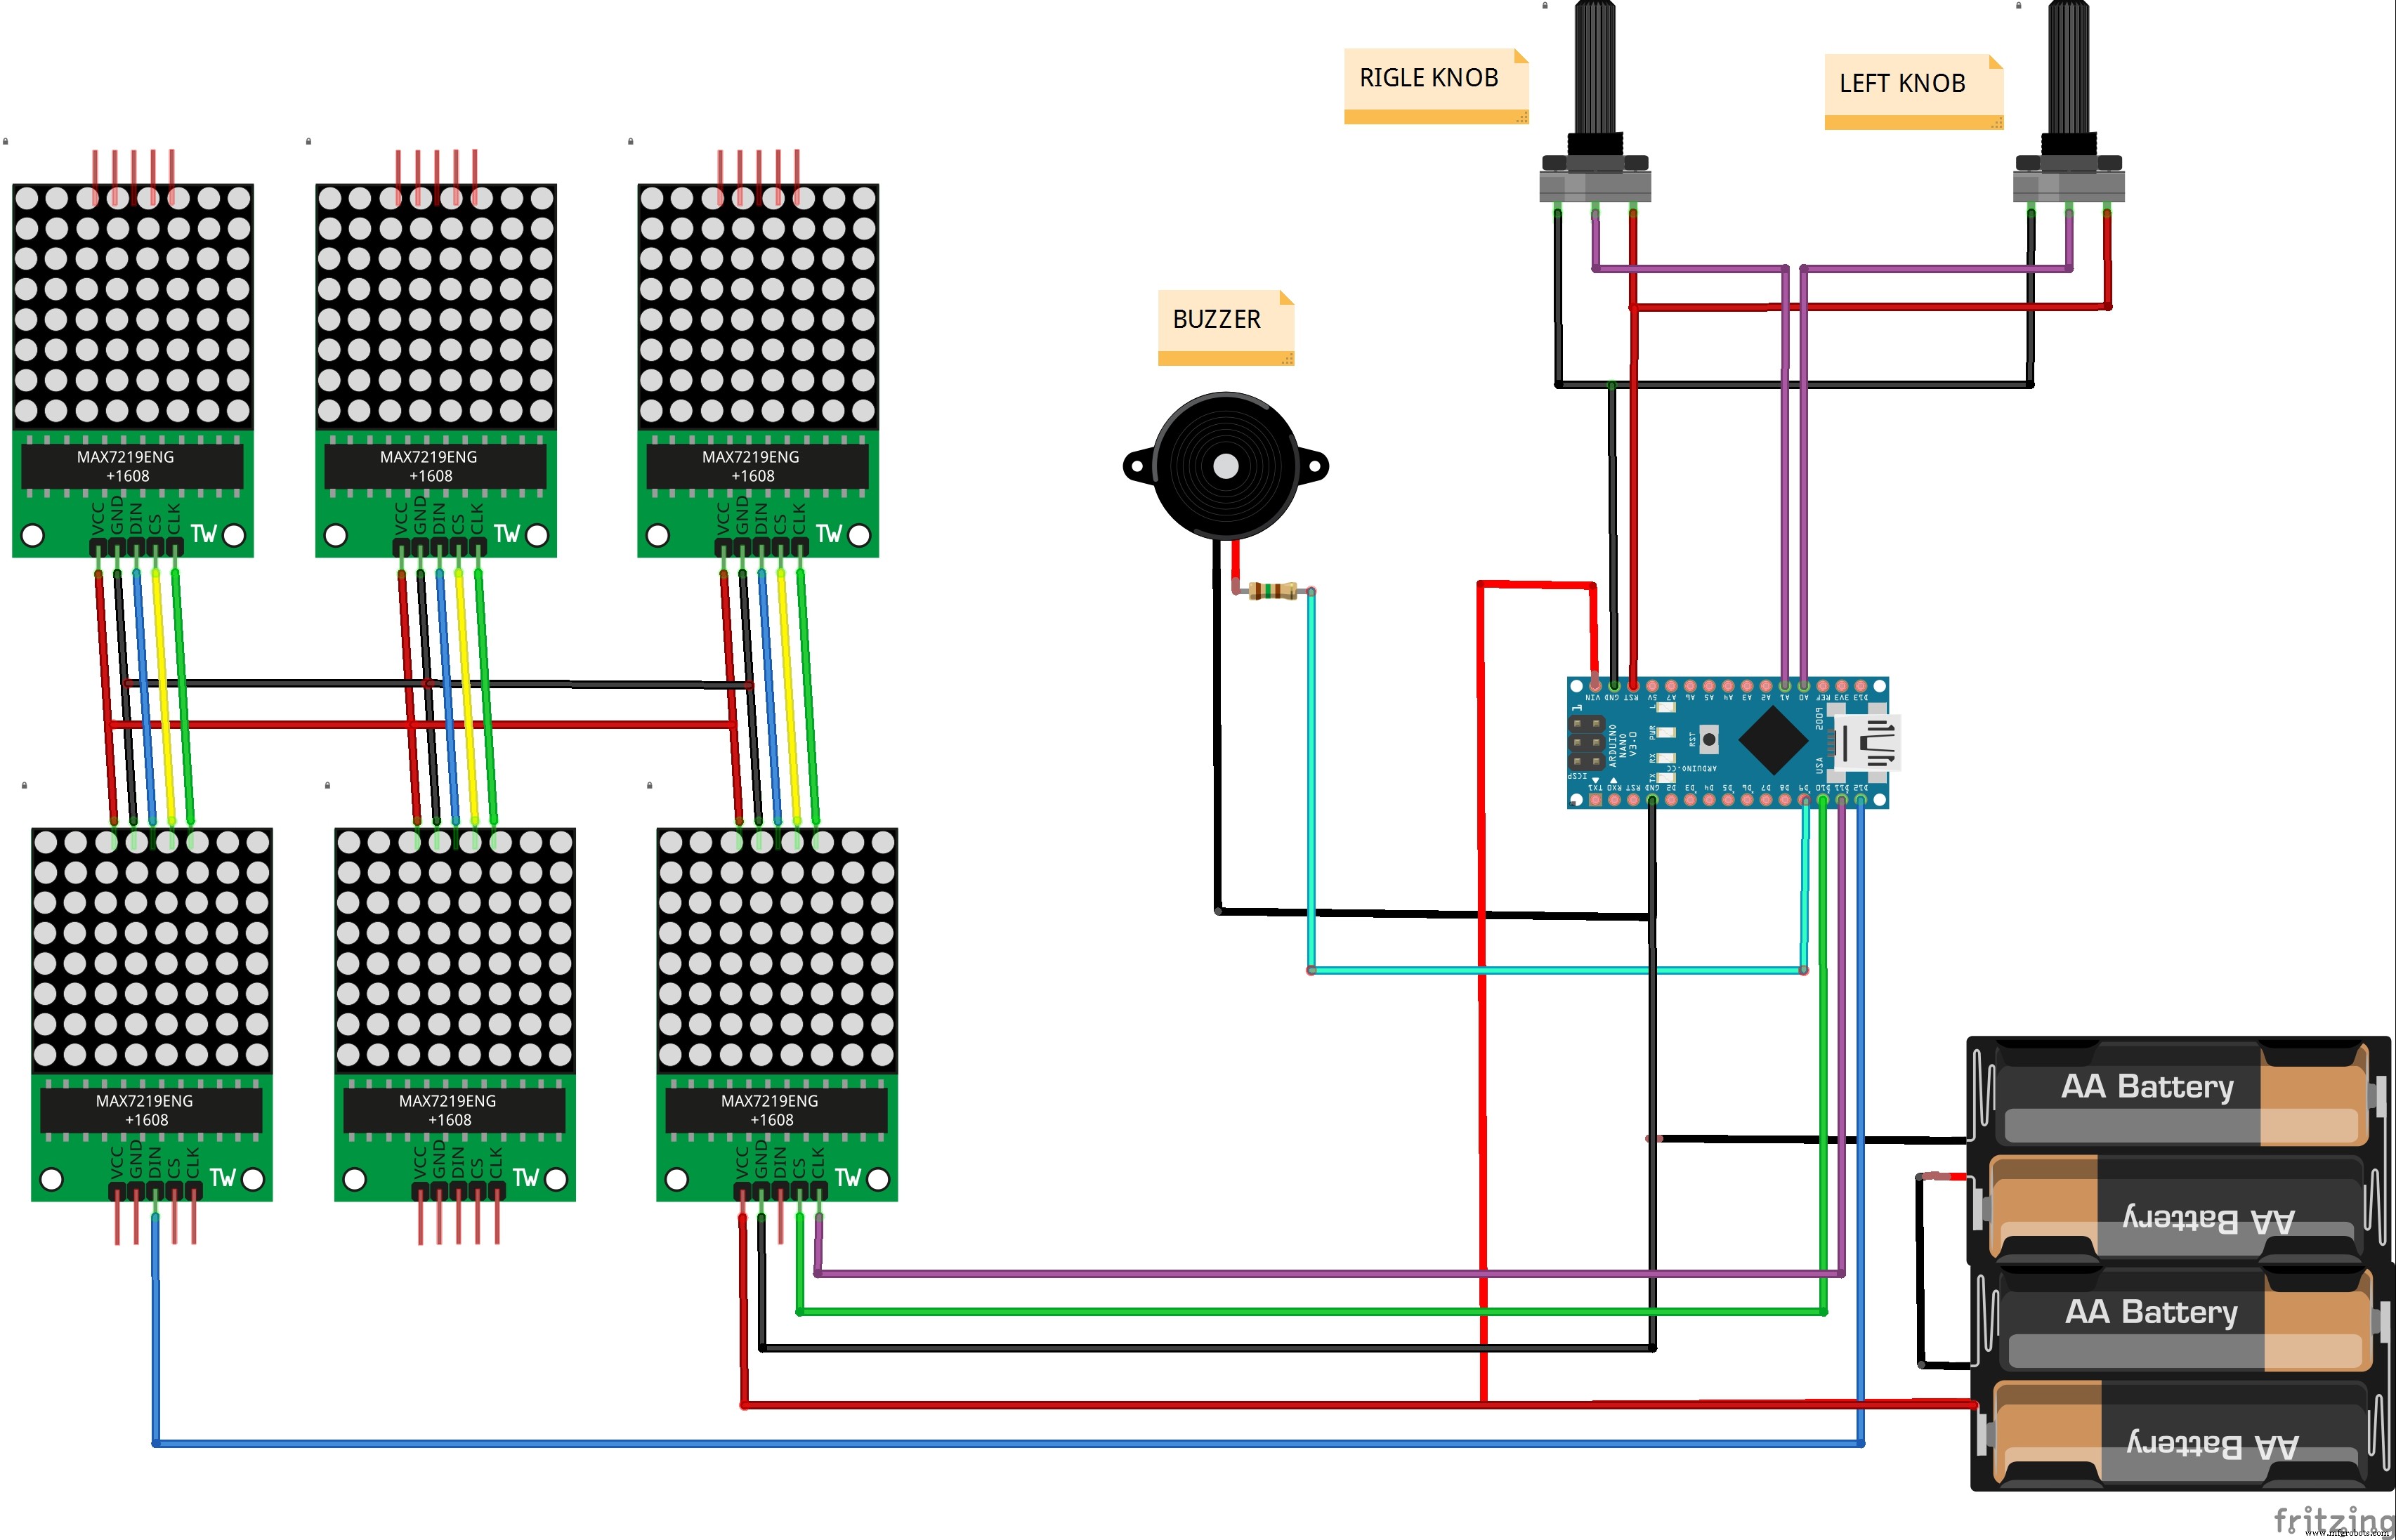
Los pines CLK y LOAD de cada módulo van conectados en paralelo. DIN del primer módulo va a Arduino, DOUT a DIN del siguiente, y así sucesivamente. Las paletas se controlan con dos potenciómetros de 10 kΩ conectados a A0 y A1 (entradas analógicas), y el zumbador al pin D9.
Al final metí el dispositivo en una caja plástica y los controles en cajas de instalación eléctrica.
Puedes descargar la librería LedControl desde: GitHub – wayoda/LedControl
Código
- code (Arduino)
code (Arduino)
// Siempre incluir la librería
#include "LedControl.h"

byte rightscore;
byte leftscore;
int toneloop = 1000;

byte pongdisplay[] = {
  // Usado al inicio para mostrar "Pong"
  B11111111, B00000000, B00001001, B00000000, B00001001, B00000000, B00000110, B00000000,
  B00000000, B00000000, B00000000, B00000000, B01110000, B00000000, B10001000, B00000000,
  B10001000, B00000000, B01110000, B00000000, B00000000, B00000000, B00000000, B00000000,
  B11110000, B00000000, B00001000, B00000000, B00001000, B00000000, B11110000, B00000000,
  B00000000, B00000000, B00000000, B00000000, B11001111, B00000000, B10001001, B00000000,
  B10001001, B00000000, B11111111, B00000000, B00000000, B00000000, B00000000, B00000000
};

byte zero[] = {  // '0' para marcador
  B00000000, B00000000, B00111100, B01000010, B01000010, B01000010, B00111100, B00000000
};
byte one[] = {   // '1'
  B00000000, B00000000, B10001000, B10000100, B11111110, B10000000, B10000000, B00000000
};
byte two[] = {   // '2'
  B00000000, B01100010, B01010001, B01010001, B01001001, B01000110, B00000000, B00000000
};
byte three[] = { // '3'
  B00000000, B00100110, B01000001, B01001001, B00110110, B00000000, B00000000, B00000000
};
byte four[] = {  // '4'
  B00000000, B00000000, B00001111, B00001000, B00001000, B11111111, B00000000, B00000000
};
byte five[] = {  // '5'
  B00000000, B00000000, B10011110, B10010010, B10010010, B11110010, B00000000, B00000000
};

byte displayevens = 0;
byte displayrow = 0;
byte displayindex = 0;
byte displayodds = 1;
unsigned long time;
unsigned long currenttime;

byte mode;
byte deflect;
byte carry;
int line;
LedControl lc = LedControl(12, 11, 10, 6);  // DIN=12, CLK=11, LOAD=10, 6 dispositivos
long randnumber;
byte dir;
int startpos;
byte row;
byte column;
long randNumber;
byte start;
byte diry;
int pass;
byte limit;

#define leftpaddle 0   // potenciómetro izquierdo en A0
#define rightpaddle 1  // potenciómetro derecho en A1

int directionpong;
int rightpongval;
int leftpongval;
byte blinkx;

byte pong[] = {  // Almacena posición de bola y paletas (48 filas = 6 matrices × 8)
  B00000000, B00000000, B00000000, B00000000, B00000000, B00000000,
  B00000000, B00000000, B00000000, B00000000, B00000000, B00000000,
  B00000000, B00000000, B00000000, B00000000, B00000000, B00000000,
  B00000000, B00000000, B00000000, B00000000, B00000000, B00000000,
  B00000000, B00000000, B00000000, B00000000, B00000000, B00000000,
  B00000000, B00000000, B00000000, B00000000, B00000000, B00000000,
  B00000000, B00000000, B00000000, B00000000, B00000000, B00000000,
  B00000000, B00000000
};

void setup() {
  pinMode(leftpaddle, INPUT);
  pinMode(rightpaddle, INPUT);
  Serial.begin(9600);

  // Inicializar 6 matrices
  for (int i = 0; i < 6; i++) {
    lc.shutdown(i, false);
    lc.setIntensity(i, 1);
    lc.clearDisplay(i);
  }

  // Mostrar "PONG" al inicio
  while (displayevens < 5) {
    while (displayrow <= 7) {
      lc.setRow(displayevens, displayrow, pongdisplay[displayindex]);
      displayrow++;
      displayindex += 2;
    }
    displayrow = 0;
    displayevens += 2;
  }
  displayrow = 0;
  displayindex = 1;
  randomSeed(analogRead(4));
  start = 1;
  time = millis();
  currenttime = millis();

  // Menú de selección de modo (3 segundos)
  while (currenttime - time < 3000) {
    leftpongval = analogRead(leftpaddle);
    leftpongval = map(leftpongval, 1023, 20, 2, 0);
    if (leftpongval == 0) {
      lc.setLed(3, 2, 7, true);
      lc.setLed(3, 3, 7, false);
      lc.setLed(3, 4, 7, false);
      mode = 1; limit = 2;
    }
    if (leftpongval == 1) {
      lc.setLed(3, 2, 7, true);
      lc.setLed(3, 3, 7, true);
      lc.setLed(3, 4, 7, false);
      mode = 2; limit = 1;
    }
    if (leftpongval == 2) {
      lc.setLed(3, 2, 7, true);
      lc.setLed(3, 3, 7, true);
      lc.setLed(3, 4, 7, true);
      mode = 3; limit = 2;
    }
    delay(50);
    lc.clearDisplay(3);
    currenttime = millis();
  }
}

void loop() {
  paddles();
  pongsim();
  displayscreen();
}

void paddles() {
  // Lee potenciómetros y actualiza array de paletas
  int searchbit;
  int carry = 0;
  leftpongval = analogRead(leftpaddle);
  leftpongval = map(leftpongval, 0, 1010, 0, 13);
  rightpongval = analogRead(rightpaddle);
  rightpongval = map(rightpongval, 1023, 20, 0, 13);

  // Limpia paletas anteriores
  pong[0] = B00000000;
  pong[1] = B00000000;
  pong[46] = B00000000;
  pong[47] = B00000000;

  // -------- Paleta derecha (matrices 4 y 5, filas 46-47) --------
  if (mode != 3) {
    if (rightpongval <= 7) {
      rightpongval = map(rightpongval, 0, 7, 7, 0);
      bitSet(pong[46], rightpongval);
      if (rightpongval - 1 >= 0) bitSet(pong[46], rightpongval - 1);
      else {
        bitSet(pong[47], 7);
        if (mode != 2) { bitSet(pong[47], 6); carry = 1; }
      }
      if (mode != 2) {
        if (carry == 0) {
          if (rightpongval - 2 >= 0) bitSet(pong[46], rightpongval - 2);
          else { bitSet(pong[47], 7); carry = 1; }
        }
      }
    }
    if (rightpongval > 7) {
      rightpongval = map(rightpongval, 8, 13, 7, limit);
      bitSet(pong[47], rightpongval);
      bitSet(pong[47], rightpongval - 1);
      if (mode != 2) bitSet(pong[47], rightpongval - 2);
    }
  } else {
    pong[46] = B11111111;
    pong[47] = B11111111;
    lc.setRow(4, 7, pong[46]);
    lc.setRow(5, 7, pong[47]);
  }

  // -------- Paleta izquierda (matrices 0 y 1, filas 0-1) --------
  carry = 0;
  if (leftpongval <= 7) {
    leftpongval = map(leftpongval, 0, 7, 7, 0);
    bitSet(pong[0], leftpongval);
    if (leftpongval - 1 >= 0) bitSet(pong[0], leftpongval - 1);
    else {
      bitSet(pong[1], 7);
      if (mode != 2) { bitSet(pong[1], 6); carry = 1; }
    }
    if (mode != 2) {
      if (carry == 0) {
        if (leftpongval - 2 >= 0) bitSet(pong[0], leftpongval - 2);
        else bitSet(pong[1], 7);
      }
    }
  }
  if (leftpongval > 7) {
    leftpongval = map(leftpongval, 8, 13, 7, limit);
    bitSet(pong[1], leftpongval);
    bitSet(pong[1], leftpongval - 1);
    if (mode != 2) bitSet(pong[1], leftpongval - 2);
  }
}

void pongsim() {
  // Colisión con paletas
  if (((line == 2 || line == 3) && diry == 0) || ((line == 44 || line == 45) && diry == 1)) {
    ball_meets_paddle();
  }

  if (start == 1) {  // Nueva partida
    randnumber = random(1, 7);
    dir = random(2);
    diry = random(2);
    if (diry == 0) {  // Movimiento abajo → arriba
      line = random(30, 34);
      bitSet(pong[line], randnumber);
    }
    if (diry == 1) {  // Movimiento arriba → abajo
      line = random(12, 16);
      bitSet(pong[line], randnumber);
    }
    start = 0;
  }

  // --- Movimiento diry == 0 (hacia arriba) ---
  if (diry == 0) {
    if (dir == 0) {  // Derecha → izquierda
      if (deflect == 0 && carry == 0) {
        line -= 2;
        pong[line] = pong[line + 2] << 1;
        pong[line + 2] = B00000000;
      }
      if (carry == 1) {
        line -= 3;
        pong[line] = B00000001;
        pong[line + 3] = B00000000;
        carry = 0; return;
      }
      if (deflect == 1) {
        line -= 2;
        pong[line] = B01000000;
        pong[line + 2] = B00000000;
        deflect = 0; dir = 1; return;
      }
      if (bitRead(pong[line], 7) == 1) {
        if (line == 3 || line == 5 || line == 7 || line == 9 || line == 11 || line == 13 ||
            line == 15 || line == 17 || line == 19 || line == 21 || line == 23 || line == 25 ||
            line == 27 || line == 29 || line == 31 || line == 33 || line == 35 || line == 37 ||
            line == 39 || line == 41 || line == 43 || line == 45) {
          carry = 1; return;
        } else {
          if (line != 2) { deflect = 1; return; }
        }
      }
    }
    if (dir == 1) {  // Izquierda → derecha
      if (deflect == 0 && carry == 0) {
        line -= 2;
        pong[line] = pong[line + 2] >> 1;
        pong[line + 2] = B00000000;
      }
      if (carry == 1) {
        line--;
        pong[line] = B10000000;
        pong[line + 1] = B00000000;
        carry = 0; return;
      }
      if (deflect == 1) {
        line -= 2;
        pong[line] = B00000010;
        pong[line + 2] = B00000000;
        deflect = 0; dir = 0; return;
      }
      if (bitRead(pong[line], 0) == 1) {
        if (line == 2 || line == 4 || line == 6 || line == 8 || line == 10 || line == 12 ||
            line == 14 || line == 16 || line == 18 || line == 20 || line == 22 || line == 24 ||
            line == 26 || line == 28 || line == 30 || line == 32 || line == 34 || line == 36 ||
            line == 38 || line == 40 || line == 42 || line == 44) {
          carry = 1; return;
        } else {
          if (line != 3) { deflect = 1; return; }
        }
      }
    }
  }

  // --- Movimiento diry == 1 (hacia abajo) ---
  if (diry == 1) {
    if (dir == 0) {  // Derecha → izquierda
      if (deflect == 0 && carry == 0) {
        line += 2;
        pong[line] = pong[line - 2] << 1;
        pong[line - 2] = B00000000;
      }
      if (carry == 1) {
        line++;
        pong[line] = B00000001;
        pong[line - 1] = B00000000;
        carry = 0; return;
      }
      if (deflect == 1) {
        line += 2;
        pong[line] = B01000000;
        pong[line - 2] = B00000000;
        deflect = 0; dir = 1; return;
      }
      if (bitRead(pong[line], 7) == 1) {
        if (line == 5 || line == 7 || line == 9 || line == 11 || line == 13 || line == 15 ||
            line == 17 || line == 19 || line == 21 || line == 23 || line == 25 || line == 27 ||
            line == 29 || line == 31 || line == 33 || line == 35 || line == 37 || line == 39 ||
            line == 41 || line == 43 || line == 45) {
          carry = 1; return;
        } else {
          if (line != 44) { deflect = 1; return; }
        }
      }
    }
    if (dir == 1) {  // Izquierda → derecha
      if (deflect == 0 && carry == 0) {
        line += 2;
        pong[line] = pong[line - 2] >> 1;
        pong[line - 2] = B00000000;
      }
      if (carry == 1) {
        line += 3;
        pong[line] = B10000000;
        pong[line - 3] = B00000000;
        carry = 0; return;
      }
      if (deflect == 1) {
        line += 2;
        pong[line] = B00000010;
        pong[line - 2] = B00000000;
        deflect = 0; dir = 0; return;
      }
      if (bitRead(pong[line], 0) == 1) {
        if (line == 2 || line == 4 || line == 6 || line == 8 || line == 10 || line == 12 ||
            line == 14 || line == 16 || line == 18 || line == 20 || line == 22 || line == 24 ||
            line == 26 || line == 28 || line == 30 || line == 32 || line == 34 || line == 36 ||
            line == 38 || line == 40 || line == 42 || line == 44) {
          carry = 1; return;
        } else {
          if (line != 45) { deflect = 1; return; }
        }
      }
    }
  }
}

void displayscreen() {
  displayevens = 0; displayrow = 0; displayindex = 0; displayodds = 1;
  while (displayevens < 5) {
    while (displayrow <= 7) {
      lc.setRow(displayevens, displayrow, pong[displayindex]);
      displayrow++; displayindex += 2;
    }
    displayrow = 0; displayevens += 2;
  }
  displayrow = 0; displayindex = 1;
  while (displayodds < 6) {
    while (displayrow < 8) {
      lc.setRow(displayodds, displayrow, pong[displayindex]);
      displayrow++; displayindex += 2;
    }
    displayrow = 0; displayodds += 2;
  }
}

void clearscreen() {
  int clearing = 0;
  while (clearing < 49) { pong[clearing] = B00000000; clearing++; }
}

void ball_meets_paddle() {
  byte search1 = 0;
  if (diry == 0) {  // Bola subiendo
    if (dir == 0) {  // Derecha → izquierda
      while (search1 < 8) {
        if (bitRead(pong[line], search1) == 1) {
          if (line == 2) {
            if (search1 != 6 && search1 != 7) {
              if (bitRead(pong[0], search1) == 1) { diry = 1; tone(9, 500, 100); }
              else if (bitRead(pong[0], search1 + 1) == 1) { diry = 1; dir = 1; tone(9, 500, 100); if (search1 == 0) carry = 1; }
              else { tone(9, 500, 300); clearscreen(); start = 1; delay(1000); scoreleft(); }
            }
            if (search1 == 6) {
              if (bitRead(pong[0], 7) == 1) { pong[2] = B01000000; dir = 1; diry = 1; tone(9, 500, 100); }
              else { tone(9, 500, 300); clearscreen(); start = 1; delay(1000); scoreleft(); }
            }
            if (search1 == 7) {
              if (bitRead(pong[0], 6) == 1) { pong[2] = B00100000; diry = 1; dir = 1; line = 2; tone(9, 500, 100); displayscreen(); }
              else { tone(9, 500, 300); clearscreen(); start = 1; delay(1000); scoreleft(); }
            }
          }
          if (line == 3) {
            if (search1 != 7) {
              if (bitRead(pong[1], search1) == 1) { diry = 1; tone(9, 500, 100); }
              else if (bitRead(pong[1], search1 + 1) == 1) { diry = 1; dir = 1; tone(9, 500, 100); }
              else { tone(9, 500, 300); clearscreen(); start = 1; delay(1000); scoreleft(); }
            }
            if (search1 == 7) {
              if (bitRead(pong[1], 7) == 1) { dir = 0; diry = 1; tone(9, 500, 100); }
              else if (bitRead(pong[0], 0) == 1) { dir = 1; diry = 1; tone(9, 500, 100); carry = 0; }
              else { tone(9, 500, 300); clearscreen(); start = 1; delay(1000); scoreleft(); }
            }
          }
        }
        search1++;
      }
    }
    if (dir == 1) {  // Izquierda → derecha
      while (search1 < 8) {
        if (bitRead(pong[line], search1) == 1) {
          if (line == 3) {
            if (search1 != 1 && search1 != 0) {
              if (bitRead(pong[1], search1) == 1) { diry = 1; tone(9, 500, 100); }
              else if (bitRead(pong[1], search1 - 1) == 1) { diry = 1; dir = 0; tone(9, 500, 100); if (search1 == 7) carry = 1; }
              else { tone(9, 500, 300); clearscreen(); start = 1; delay(1000); scoreleft(); }
            }
            if (search1 == 1) {
              if (bitRead(pong[1], 0) == 1) { pong[3] = B00000010; dir = 0; diry = 1; tone(9, 500, 100); }
              else { tone(9, 500, 300); clearscreen(); start = 1; delay(1000); scoreleft(); }
            }
            if (search1 == 0) {
              if (bitRead(pong[1], 0) == 1) { pong[3] = B00000100; diry = 1; dir = 0; line = 3; tone(9, 500, 100); displayscreen(); }
              else { tone(9, 500, 300); clearscreen(); start = 1; delay(1000); scoreleft(); }
            }
          }
          if (line == 2) {
            if (search1 != 0) {
              if (bitRead(pong[0], search1) == 1) { diry = 1; tone(9, 500, 100); }
              else if (bitRead(pong[0], search1 - 1) == 1) { diry = 1; dir = 0; tone(9, 500, 100); }
              else { tone(9, 500, 300); clearscreen(); start = 1; delay(1000); scoreleft(); }
            }
            if (search1 == 0) {
              if (bitRead(pong[0], 0) == 1) { line = 2; dir = 1; diry = 1; tone(9, 500, 100); return; }
              else if (bitRead(pong[1], 7) == 1) { diry = 1; dir = 0; tone(9, 500, 100); carry = 0; }
              else { tone(9, 500, 300); clearscreen(); start = 1; delay(1000); scoreleft(); }
            }
          }
        }
        search1++;
      }
    }
  }

  // --- diry == 1 (bola bajando) ---
  if (diry == 1) {
    if (dir == 0) {  // Derecha → izquierda
      while (search1 < 8) {
        if (bitRead(pong[line], search1) == 1) {
          if (line == 44) {
            if (search1 != 6 && search1 != 7) {
              if (bitRead(pong[46], search1) == 1) { diry = 0; tone(9, 500, 100); }
              else if (bitRead(pong[46], search1 + 1) == 1) { diry = 0; dir = 1; tone(9, 500, 100); if (search1 == 0) carry = 1; }
              else { tone(9, 500, 300); clearscreen(); start = 1; delay(1000); scoreright(); }
            }
            if (search1 == 6) {
              if (bitRead(pong[46], 7) == 1) { dir = 1; diry = 0; tone(9, 500, 100); }
              else { tone(9, 500, 300); clearscreen(); start = 1; delay(1000); scoreright(); }
            }
            if (search1 == 7) {
              if (bitRead(pong[46], 6) == 1) { pong[44] = B00100000; diry = 0; dir = 1; tone(9, 500, 100); displayscreen(); line = 44; return; }
            }
          }
          if (line == 45) {
            if (search1 != 7) {
              if (bitRead(pong[47], search1) == 1) { diry = 0; tone(9, 500, 100); }
              else if (bitRead(pong[47], search1 + 1) == 1) { diry = 0; dir = 1; tone(9, 500, 100); }
              else { tone(9, 500, 300); clearscreen(); start = 1; delay(1000); scoreright(); }
            }
            if (search1 == 7) {
              if (bitRead(pong[47], 7) == 1) { line = 45; dir = 0; diry = 0; tone(9, 500, 100); }
              else if (bitRead(pong[46], 0) == 1) { dir = 1; diry = 0; tone(9, 500, 100); carry = 0; }
              else { tone(9, 500, 300); clearscreen(); start = 1; delay(1000); scoreright(); }
            }
          }
        }
        search1++;
      }
    }
    if (dir == 1) {  // Izquierda → derecha
      while (search1 < 8) {
        if (bitRead(pong[line], search1) == 1) {
          if (line == 45) {
            if (search1 != 1 && search1 != 0) {
              if (bitRead(pong[47], search1) == 1) { diry = 0; tone(9, 500, 100); }
              else if (bitRead(pong[47], search1 - 1) == 1) { diry = 0; dir = 0; tone(9, 500, 100); if (search1 == 7) carry = 1; }
              else { tone(9, 500, 300); clearscreen(); start = 1; delay(1000); scoreright(); }
            }
            if (search1 == 1) {
              if (bitRead(pong[47], 0) == 1) { pong[43] = B00000010; dir = 0; diry = 0; tone(9, 500, 100); }
              else { tone(9, 500, 300); clearscreen(); start = 1; delay(1000); scoreright(); }
            }
            if (search1 == 0) {
              if (bitRead(pong[47], 1) == 1) { pong[45] = B00000100; diry = 0; dir = 0; line = 45; tone(9, 500, 100); displayscreen(); }
              else { tone(9, 500, 300); clearscreen(); start = 1; delay(1000); scoreright(); }
            }
          }
          if (line == 44) {
            if (search1 != 0) {
              if (bitRead(pong[46], search1) == 1) { diry = 0; tone(9, 500, 100); }
              else if (bitRead(pong[46], search1 - 1) == 1) { diry = 0; dir = 0; tone(9, 500, 100); }
              else { tone(9, 500, 300); clearscreen(); start = 1; delay(1000); scoreright(); }
            }
            if (search1 == 0) {
              if (bitRead(pong[46], 0) == 1) { pong[44] = B00000001; line = 44; dir = 1; diry = 0; tone(9, 500, 100); }
              else if (bitRead(pong[47], 7) == 1) { dir = 0; diry = 0; tone(9, 500, 100); carry = 0; }
              else { tone(9, 500, 300); clearscreen(); start = 1; delay(1000); scoreright(); }
            }
          }
        }
        search1++;
      }
    }
  }
  pass = 1; search1 = 0;
}

void scoreleft() {
  clearscreen(); rightscore++; setscore(); displayscreen();
  if (rightscore == 5) {
    while (blinkx++ < 4) { clearscreen(); displayscreen(); delay(500); setscore(); displayscreen(); delay(500); }
    blinkx = 0; rightscore = 0; leftscore = 0;
  } else delay(2000);
  clearscreen();
}

void scoreright() {
  clearscreen(); leftscore++; setscore(); displayscreen();
  if (leftscore == 5) {
    while (blinkx++ < 4) { clearscreen(); displayscreen(); delay(500); setscore(); displayscreen(); delay(500); }
    blinkx = 0; rightscore = 0; leftscore = 0;
  } else delay(2000);
  clearscreen();
}

void setscore() {
  byte setScoreLoop = 0;
  while (setScoreLoop <= 7) {
    if (leftscore == 0) pong[setScoreLoop * 2] = zero[setScoreLoop];
    if (leftscore == 1) pong[setScoreLoop * 2] = one[setScoreLoop];
    if (leftscore == 2) pong[setScoreLoop * 2] = two[setScoreLoop];
    if (leftscore == 3) pong[setScoreLoop * 2] = three[setScoreLoop];
    if (leftscore == 4) pong[setScoreLoop * 2] = four[setScoreLoop];
    if (leftscore == 5) pong[setScoreLoop * 2] = five[setScoreLoop];
    if (rightscore == 0) pong[32 + (setScoreLoop * 2)] = zero[setScoreLoop];
    if (rightscore == 1) pong[32 + (setScoreLoop * 2)] = one[setScoreLoop];
    if (rightscore == 2) pong[32 + (setScoreLoop * 2)] = two[setScoreLoop];
    if (rightscore == 3) pong[32 + (setScoreLoop * 2)] = three[setScoreLoop];
    if (rightscore == 4) pong[32 + (setScoreLoop * 2)] = four[setScoreLoop];
    if (rightscore == 5) pong[32 + (setScoreLoop * 2)] = five[setScoreLoop];
    setScoreLoop++;
  }
  pong[20] = B00011000;
  pong[22] = B00011000;
  pong[24] = B00011000;
}
Esquemático
Unopad: Controlador MIDI Arduino para Ableton Live sin complicaciones
Construye un lanzador automático LEGO Star Wars con Arduino Uno
Proceso de manufactura
- Construye un Juego Giroscópico en Tiempo Real con Arduino Nano y Sensor MPU-6050
- Construya el clásico juego Pong en Arduino UNO con pantalla OLED: Tutorial paso a paso
- Mando USB para juegos DIY con Arduino – Construye tu propio gamepad de alto rendimiento
- Alcancía Inteligente: Controla un Aceptador de Monedas con Arduino Nano
- Construye una consola Pong 24×16 LED con Arduino Nano y MAX7219
- Construye un juego Tetris con Arduino Nano en matriz LED 16x8 DIY
- Controla un LED por Bluetooth con Arduino – Guía DIY paso a paso
- Pixel Chaser: Juego LED Interactivo de Un Toque con Arduino Nano
- Control de Matriz LED 8×8 con Arduino Uno: Guía Paso a Paso
- Pong Neón en Matriz NeoPixel con Arduino Nano
- Medición Precisa de Radiación Solar con Arduino UNO y Shield Ethernet